Human in the loop
I build robots and random mechanisms.
Mostly firmware and motion control.
Motors & actuators (a lot of actuators).
The occasional over-engineered gadget.
About
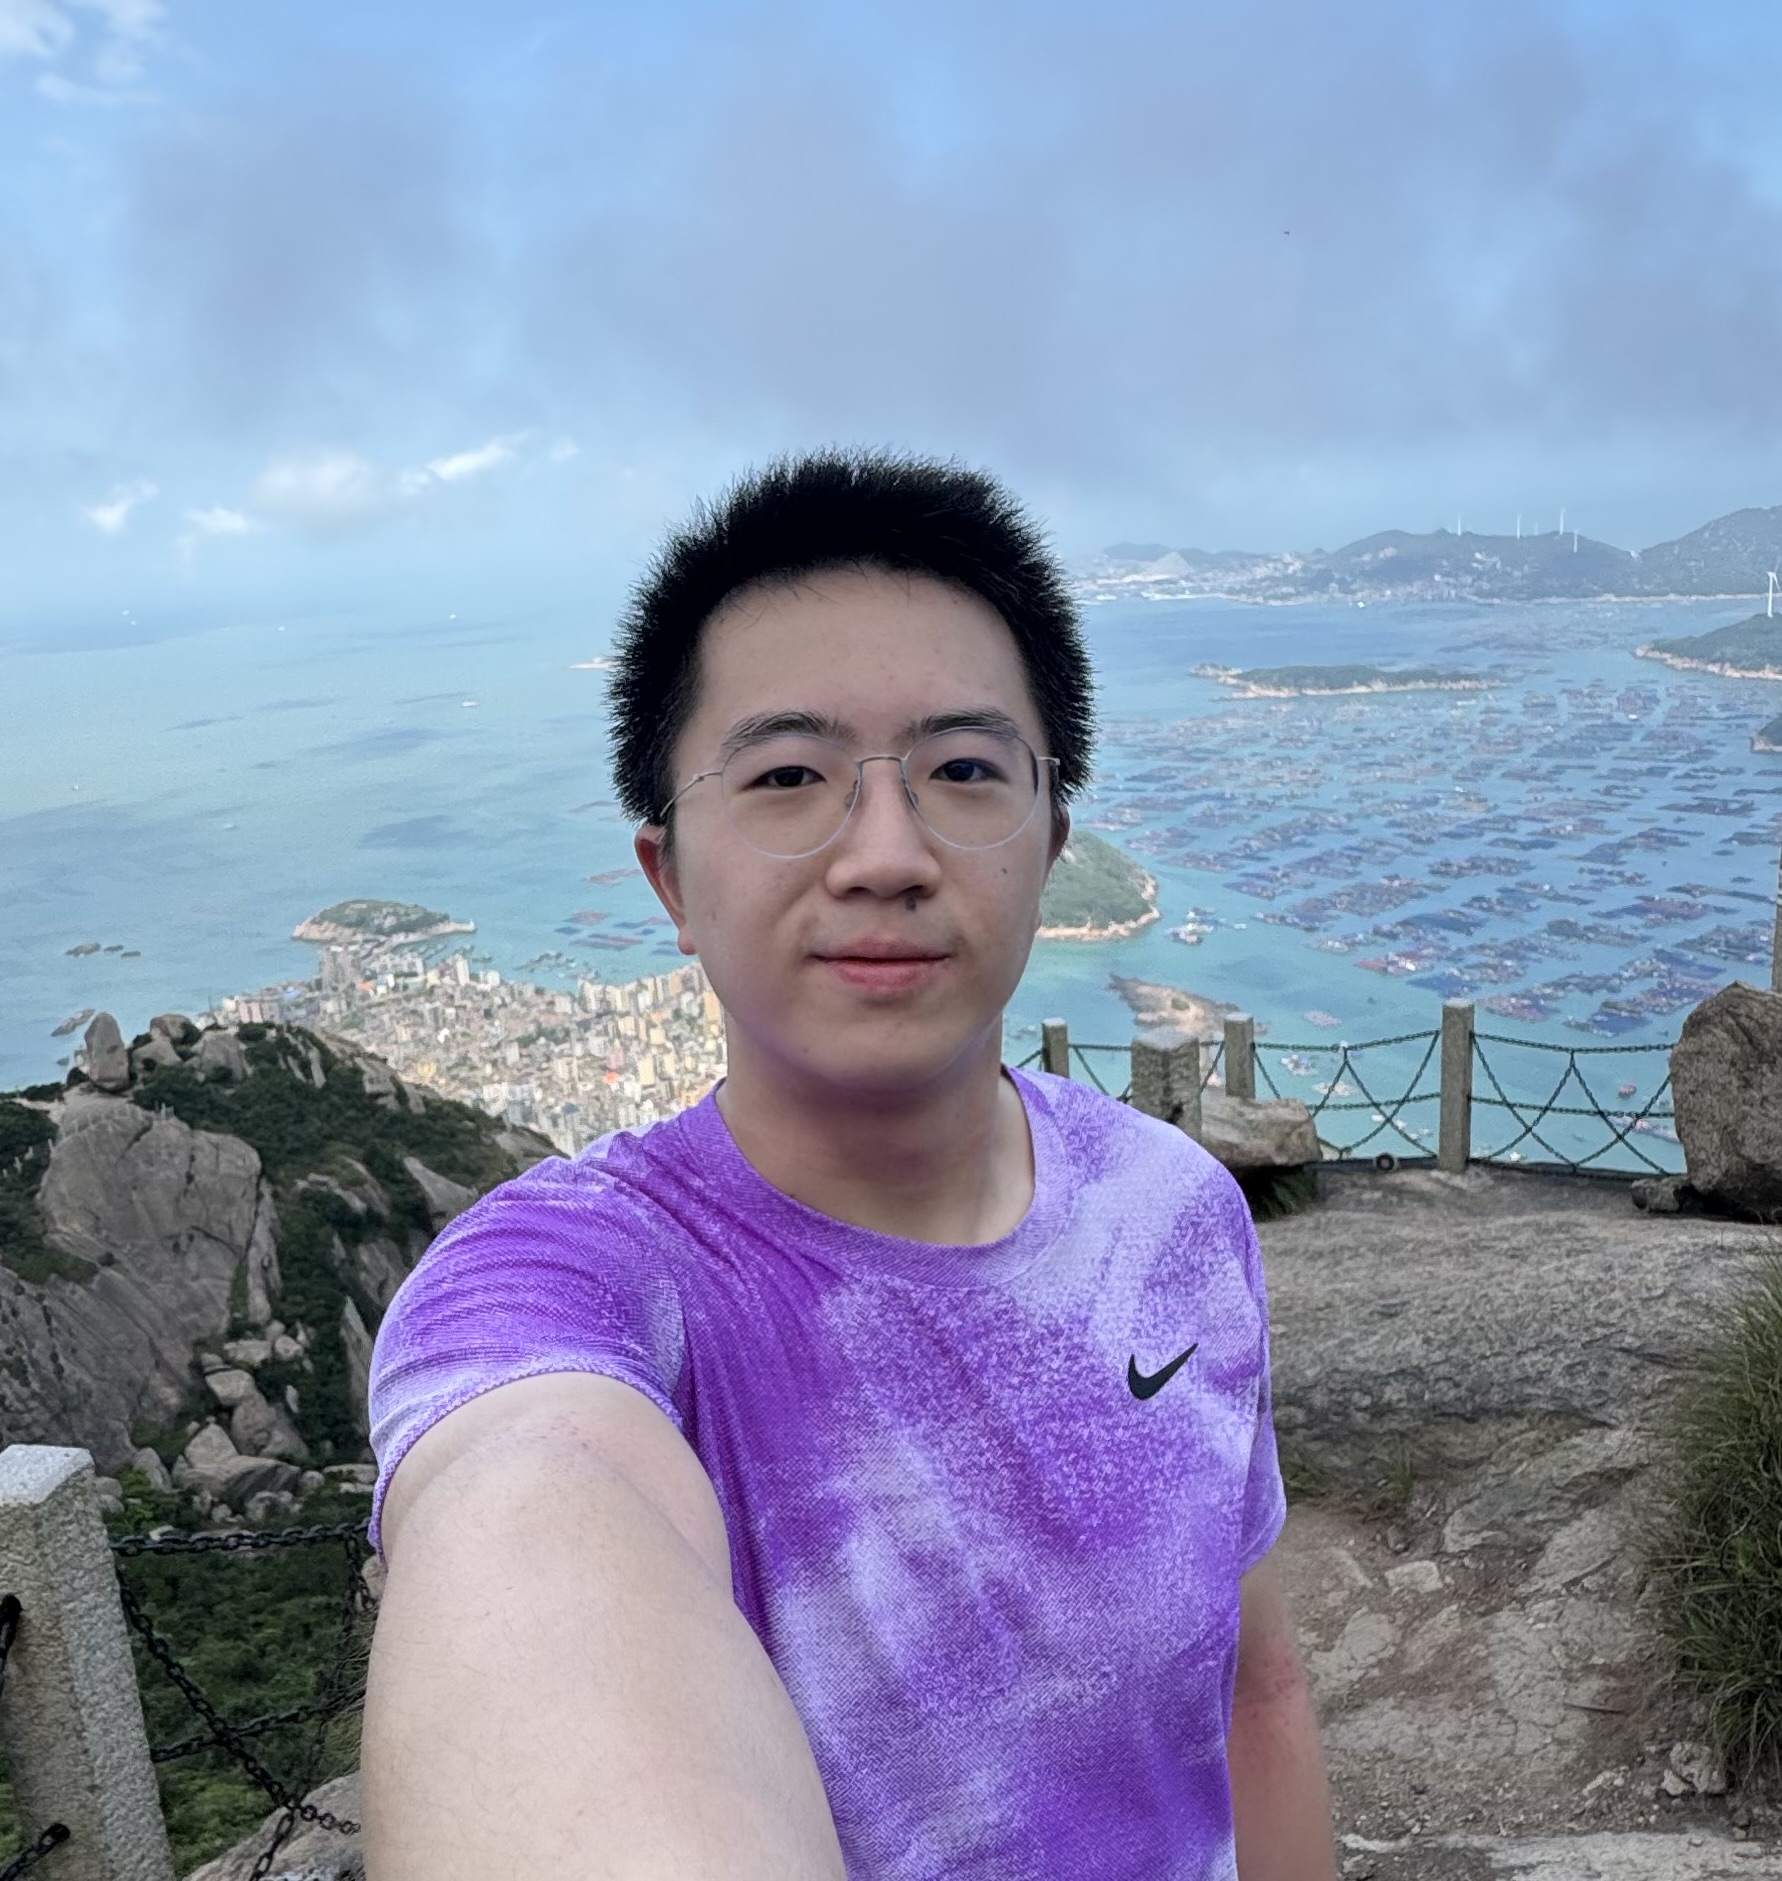
I am a mechanical engineering student at Purdue. I love exploring mechanisms invented hand in hand with their materials, including compliant mechanisms and biomimetics. My current research is on robotic muscles, specifically dielectric elastomer actuators. They are close cousins of the HASEL actuators already in industry. They peak near 580 W/kg (about double human muscle) and pull joints through tendons with no gearboxes or linkages.
My newer fascination is within the industrial sector. At Pratt & Whitney, I worked with ABB robots and noticed two issues up close. First, how slowly a repair cell comes to life. Second, how quickly expertise is lost.
Why deployment is SO SLOW
A solutions company consults first, then months go to shipping and installing the hardware, followed by training and certifying the crew. After deployment, every breakdown waits on an outside repair, adding to the 27 hours a month large plants already lose to unplanned downtime. All told, it costs four to five times the arm's price. Even then, no digital twin yet fuses live data from every brand of machine on the floor, so people still make the calls.
Why expertise walks out the door
Veteran on-shop staff averages 9.6 years of tenure, young hires 2.7, so expertise retires before it transfers. An exoskeleton that records a veteran's motions could replay them to guide the next hire, passing down know-how the veteran never had to write down. This could also bring down the cost of training and certifying new staff.
I want to build cheaper, task-oriented robots. For most factory tasks, the right form is rarely humanoid.
Why actuators set the price
Off-the-shelf modular actuators already let integrators snap custom robots together, but actuators are a third of a robot's value. Cheaper, task-matched modules would cut both the price and the custom engineering behind every deployment.
My research attacks the actuator problem from two sides. One is cost: developing affordable, high-performance artificial muscles from my lab. The other is building up to hybrid joints/arms that pair motors with muscles that sense their own motion. I am motivated to join an early-stage team shipping affordable, task-shaped robots, starting from actuator R&D. Interested in my ponderings? Say hi below.
Experience


Repair Engineering Intern · Pratt & Whitney Shanghai Engine Center
May 2026 – Aug 2026
Shanghai, China
A summer inside a commercial engine overhaul shop. Root cause studies, first article inspections, and the paperwork that proves a repair can be trusted.
Read more ⟶

Undergraduate Researcher · Bionic Interfaces Prototyping Lab, Purdue ME
Jan 2026 – Present
West Lafayette, IN
Fabrication and COMSOL modeling for a soft-actuator lab. 100+ devices coated, measured, and matched to simulation.
Read more ⟶
Undergraduate Researcher · RAAD Lab, Purdue ME
Jan 2026 – May 2026
West Lafayette, IN
Designed and bench-tested the servo valve node that lets a soft bellow array reconfigure on one air line.
Read more ⟶
Flight Systems Researcher · AIDA3, Purdue's aviation AI center
Jan 2025 – Dec 2025
West Lafayette, IN
Taxiway graphs, a runway geofence, and hangar flight tests for an autonomous cargo plane.
Read more ⟶
Barista · Lavazza at Purdue
Jan 2025 – Present
West Lafayette, IN
Espresso and latte art at a campus café. Pouring a clean rosetta is a process-control problem. I treat it like one.
Read more ⟶
Lead Software Researcher · PURT
Jan 2025 – Aug 2025
West Lafayette, IN
Led the software team. Owned the ROS 2 pipeline, the RRT* planner, and the land-or-abort landing code.
Read more ⟶Projects
Personal
Dielectric Elastomer Actuators
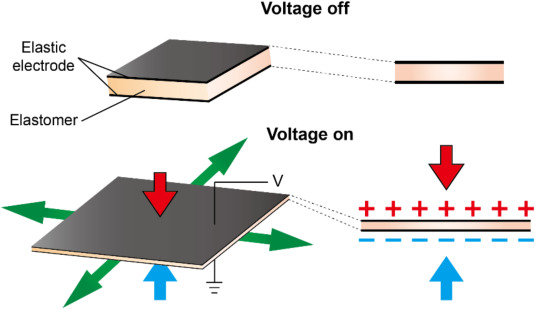
A soft capacitor that moves like muscle when you put a few kilovolts across it. 100+ devices built, work in progress.
- Soft Robotics
- COMSOL
- Fabrication
- DEAs
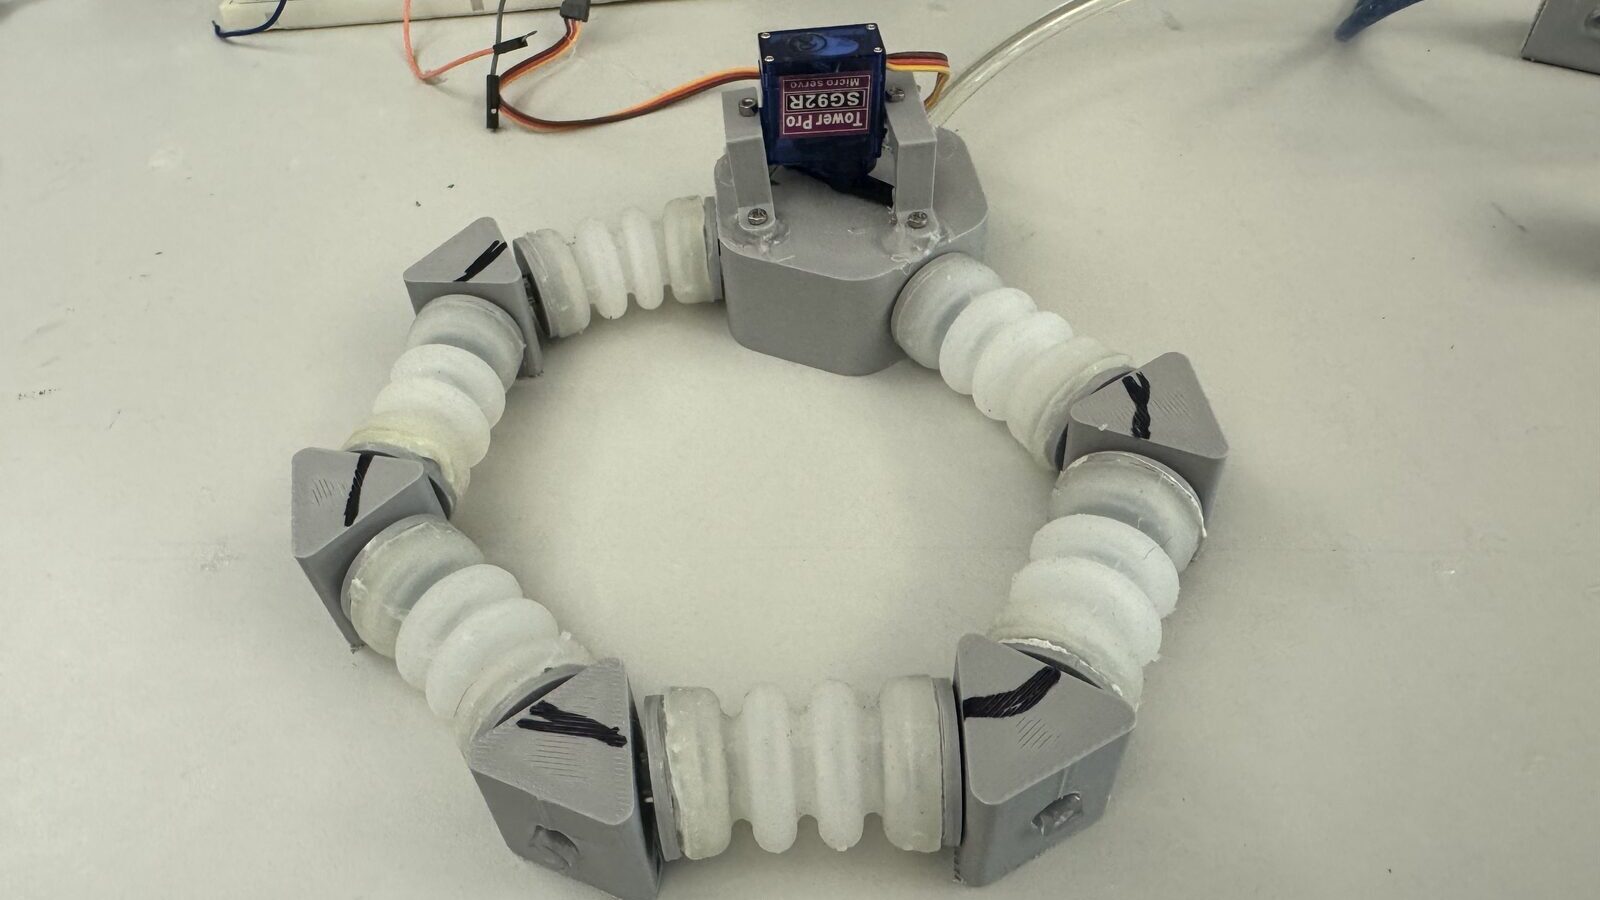
Reconfigurable Pneumatic Actuator Array
One air line, one servo, and a spinning valve that picks which soft bellow inflates next. Undergrad research on reconfigurable air-powered soft robot arrays.
- Soft Robotics
- Pneumatics
- 3D Printing
- Silicone Molding
- Abaqus
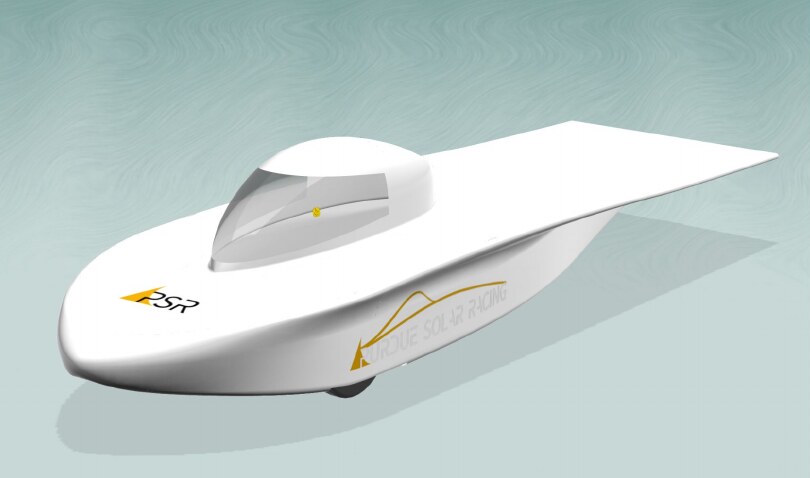
Solar Car Aeroshell
Purdue Solar Racing's 2026 aeroshell, narrowed down from a three-way shape debate to cured carbon fiber. 30+ CFD runs to pick and sharpen it, VARTM to build it.
- CFD
- ANSYS Fluent
- Composites
- Siemens NX
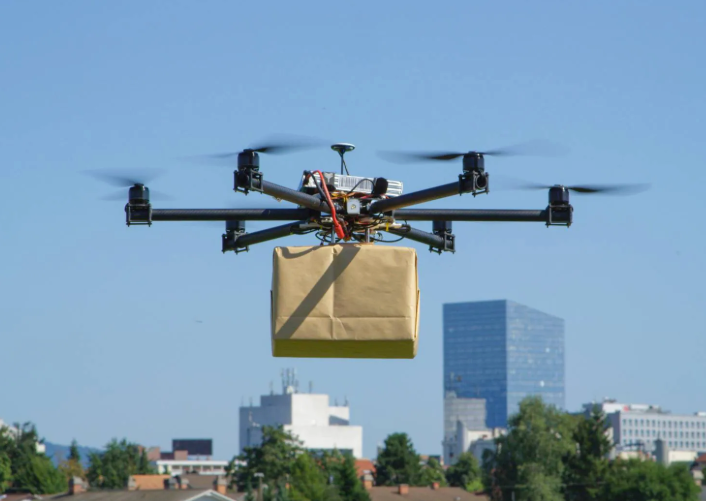
Autonomous Drone Delivery Stack
The navigation brain for a campus drone delivery system. A GPS pin goes in. Nav2 plans the mission. A simulated hexacopter flies it.
- ROS 2
- Nav2
- PX4
- Gazebo
- C++
- SLAM
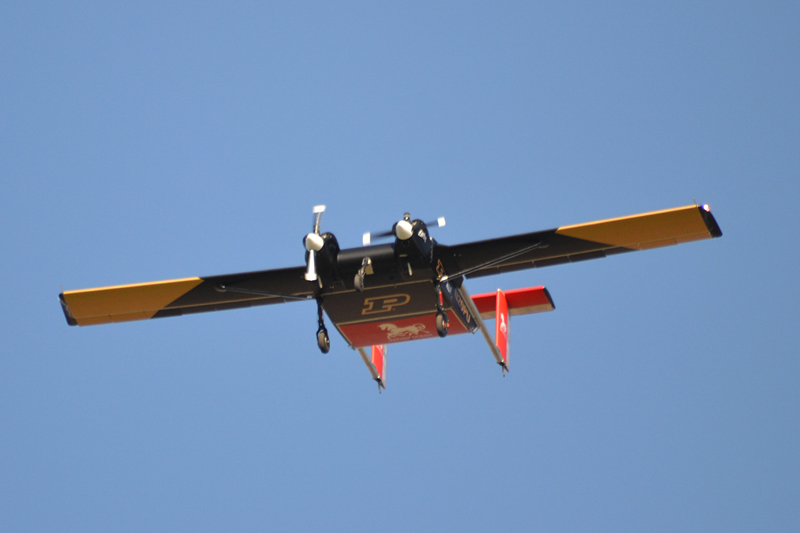
Flight Path Planning for a Cargo UAV
Navigation research for the Windracers ULTRA, an autonomous cargo plane with a 200 kg payload. Parsing O'Hare into a 6,209-node taxiway graph the planner can search, and keeping the aircraft inside its runway corridor.
- UAV
- Path Planning
- Graph Search
- OSMnx
- Python
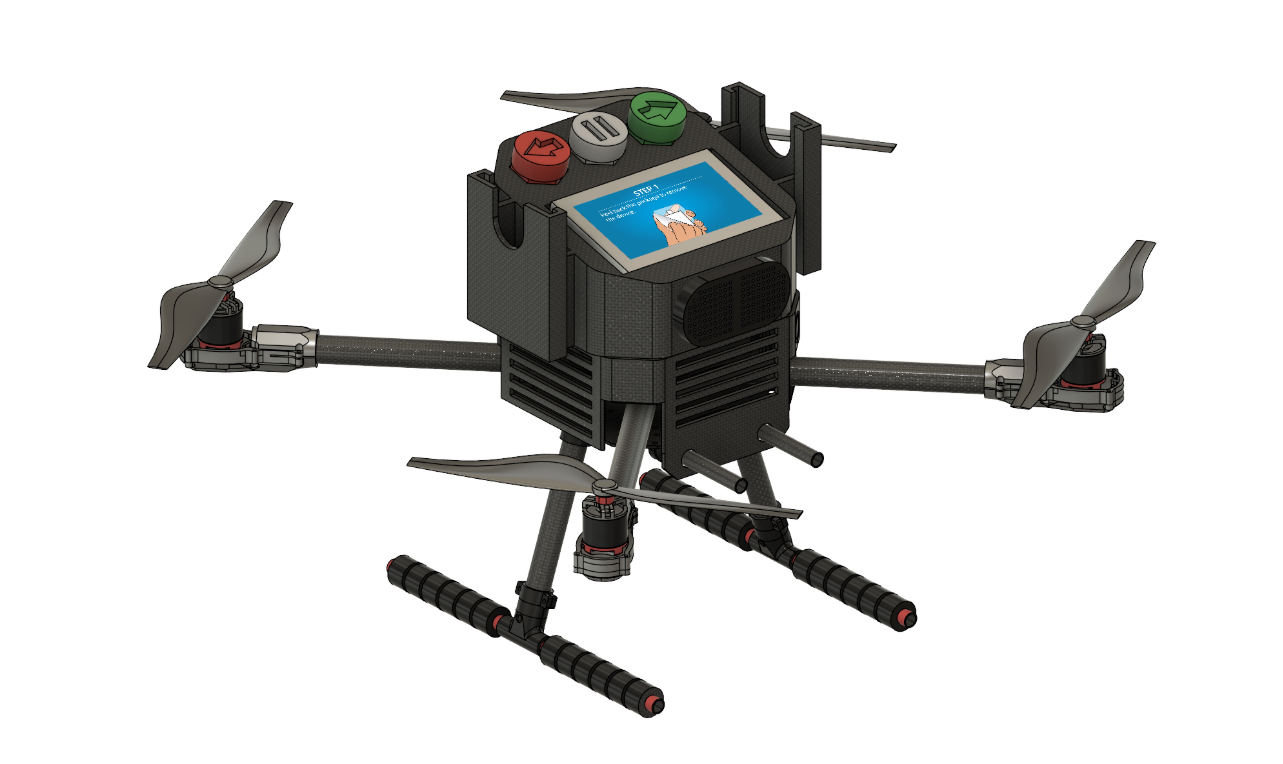
Narcan Delivery Drone
A drone that flies Narcan to opioid overdoses ahead of the ambulance. Full autonomy pipeline in ROS 2 covering navigation, precision landing, and payload delivery.
- ROS 2
- UAV
- Path Planning
- Gazebo
- PX4
Class
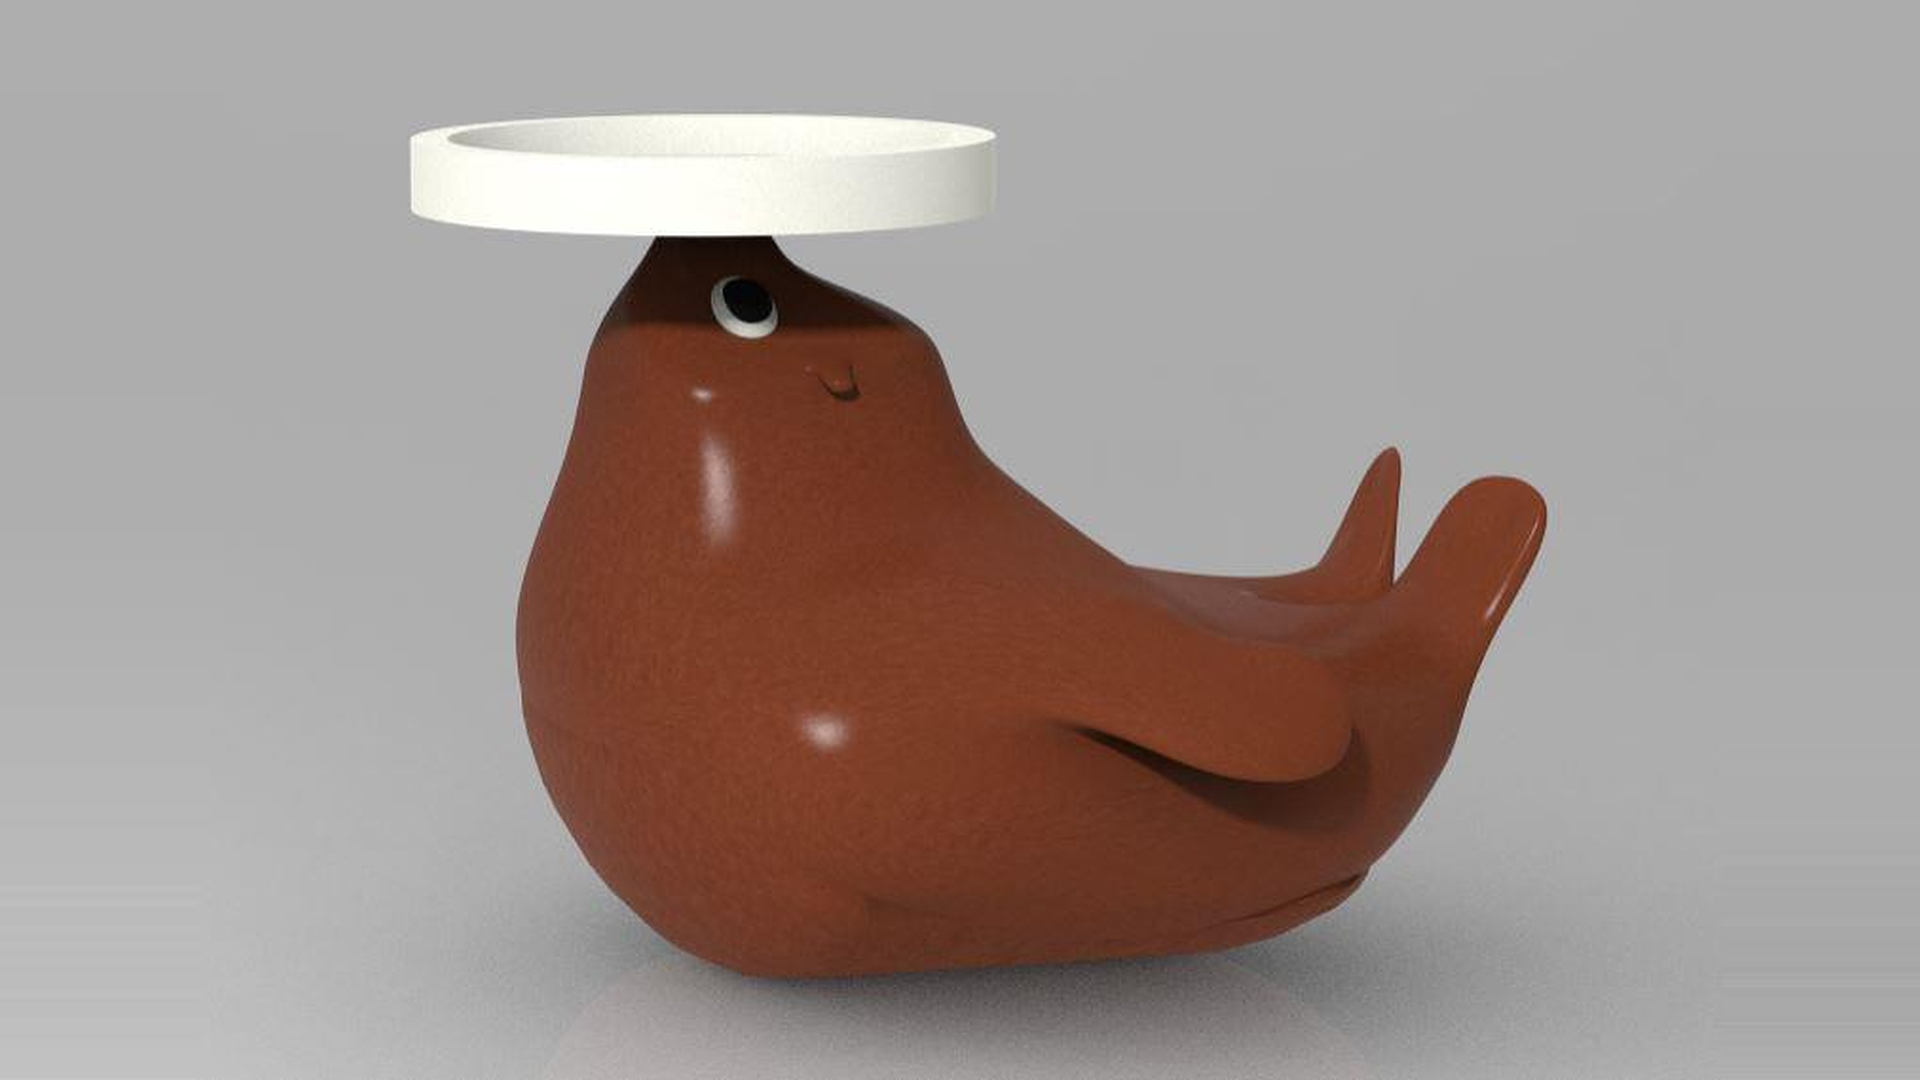
Self-Balancing Sea Lion
An actively stabilized toy that balances objects on his nose. Creo surface modeling, a Dyneema capstan drive, and PID control stuffed inside a chubby 3D-printed sea lion.
- Creo Parametric
- Mechatronics
- PID Control
- 3D Printing
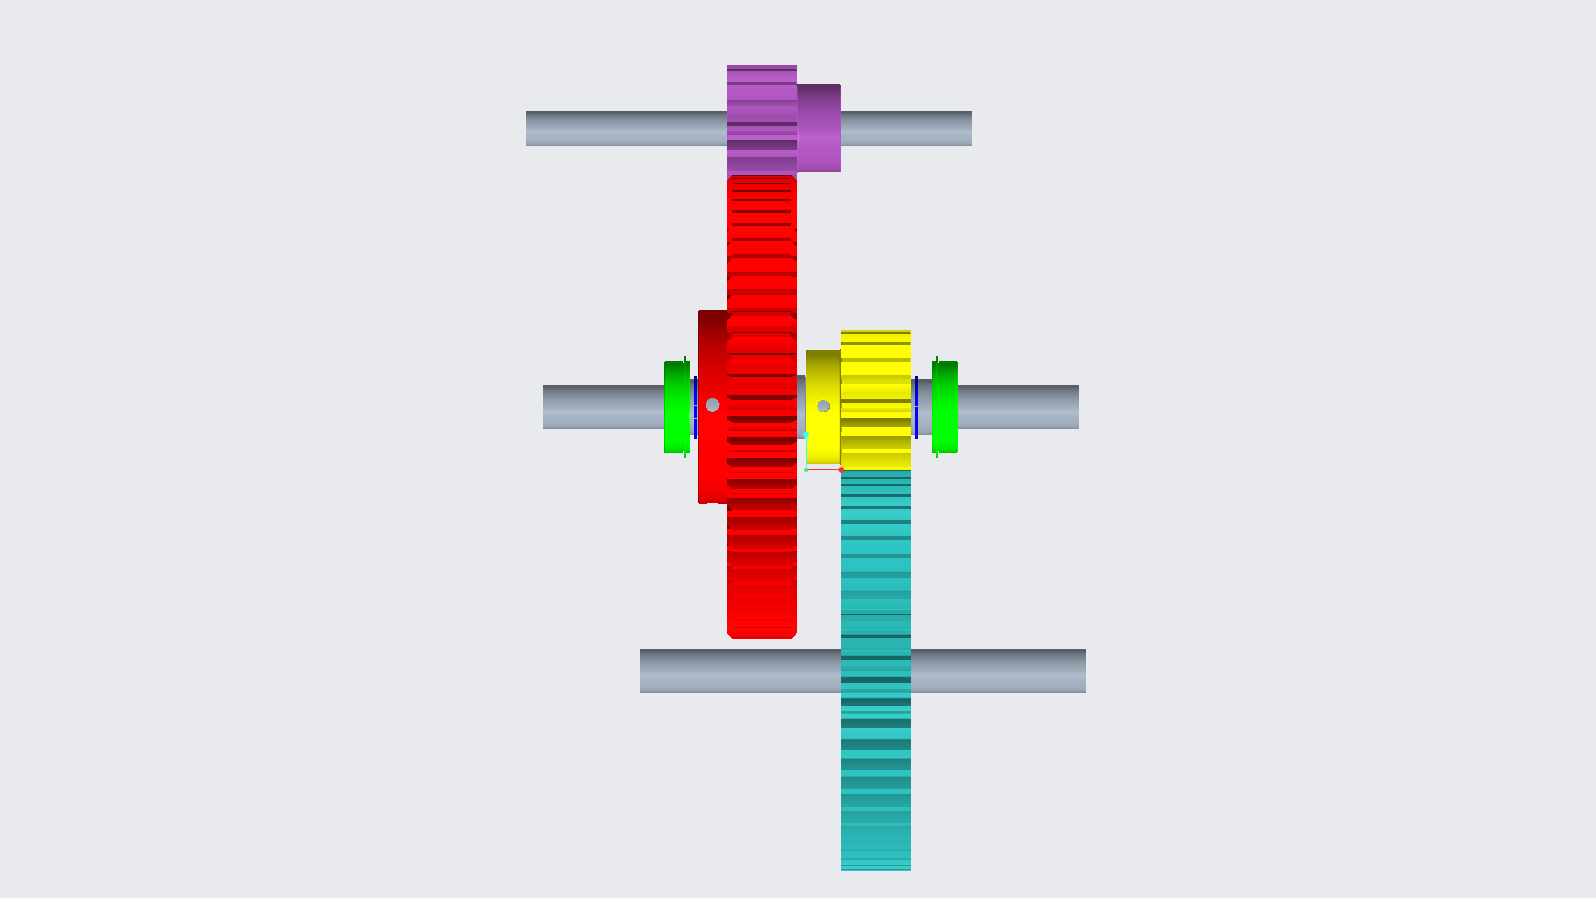
Two-Stage Spur Gearbox for an Electric Go-Kart
A 20:1 reduction gearbox designed from the shaft out. Gears picked from the catalog, the shaft sized to never fail from fatigue, and every gear, bearing, and key proven against industry checks.
- Machine Design
- Gears
- Shaft Fatigue
- AGMA
- CAD
- MATLAB
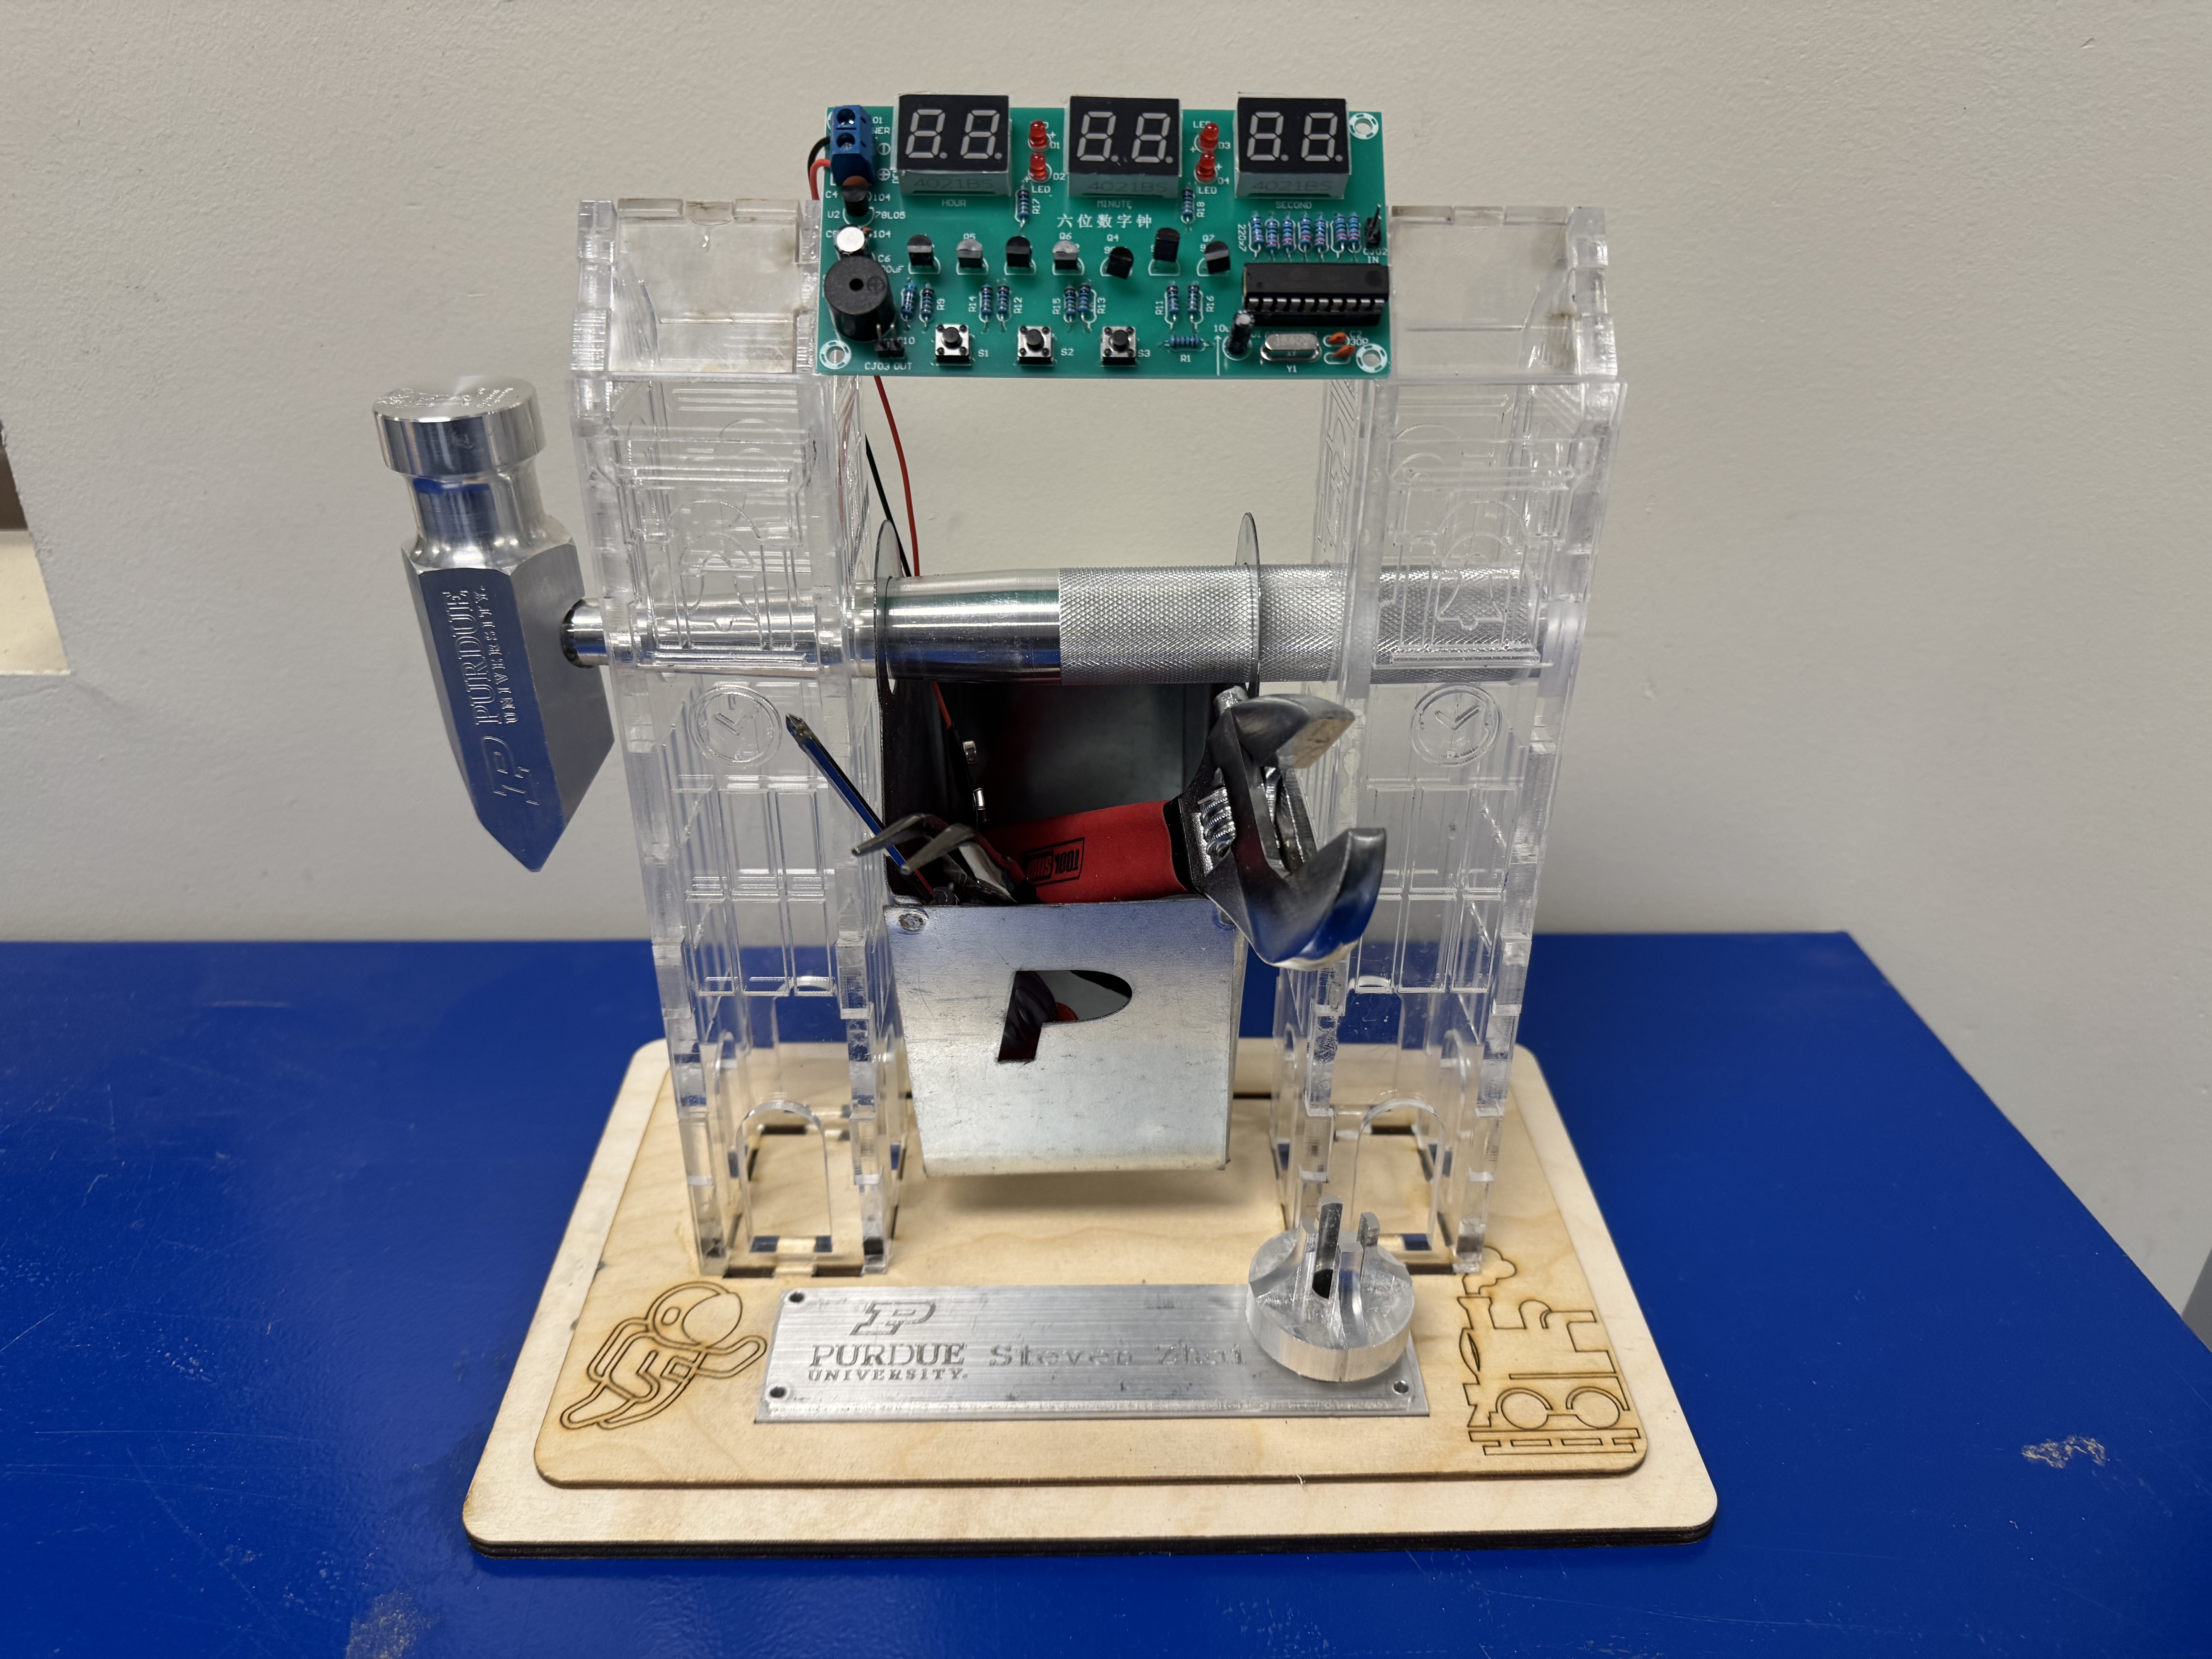
Dual Clock-Tower Pen Holder
A hammer turned into a desk organizer. Laser-cut and brake-formed from plywood, acrylic, and sheet metal, held together by tabs and glue, no fasteners.
- DFM/DFA
- Laser Cutting
- Sheet Metal
- CAD
- SolidWorks
- Rapid Prototyping
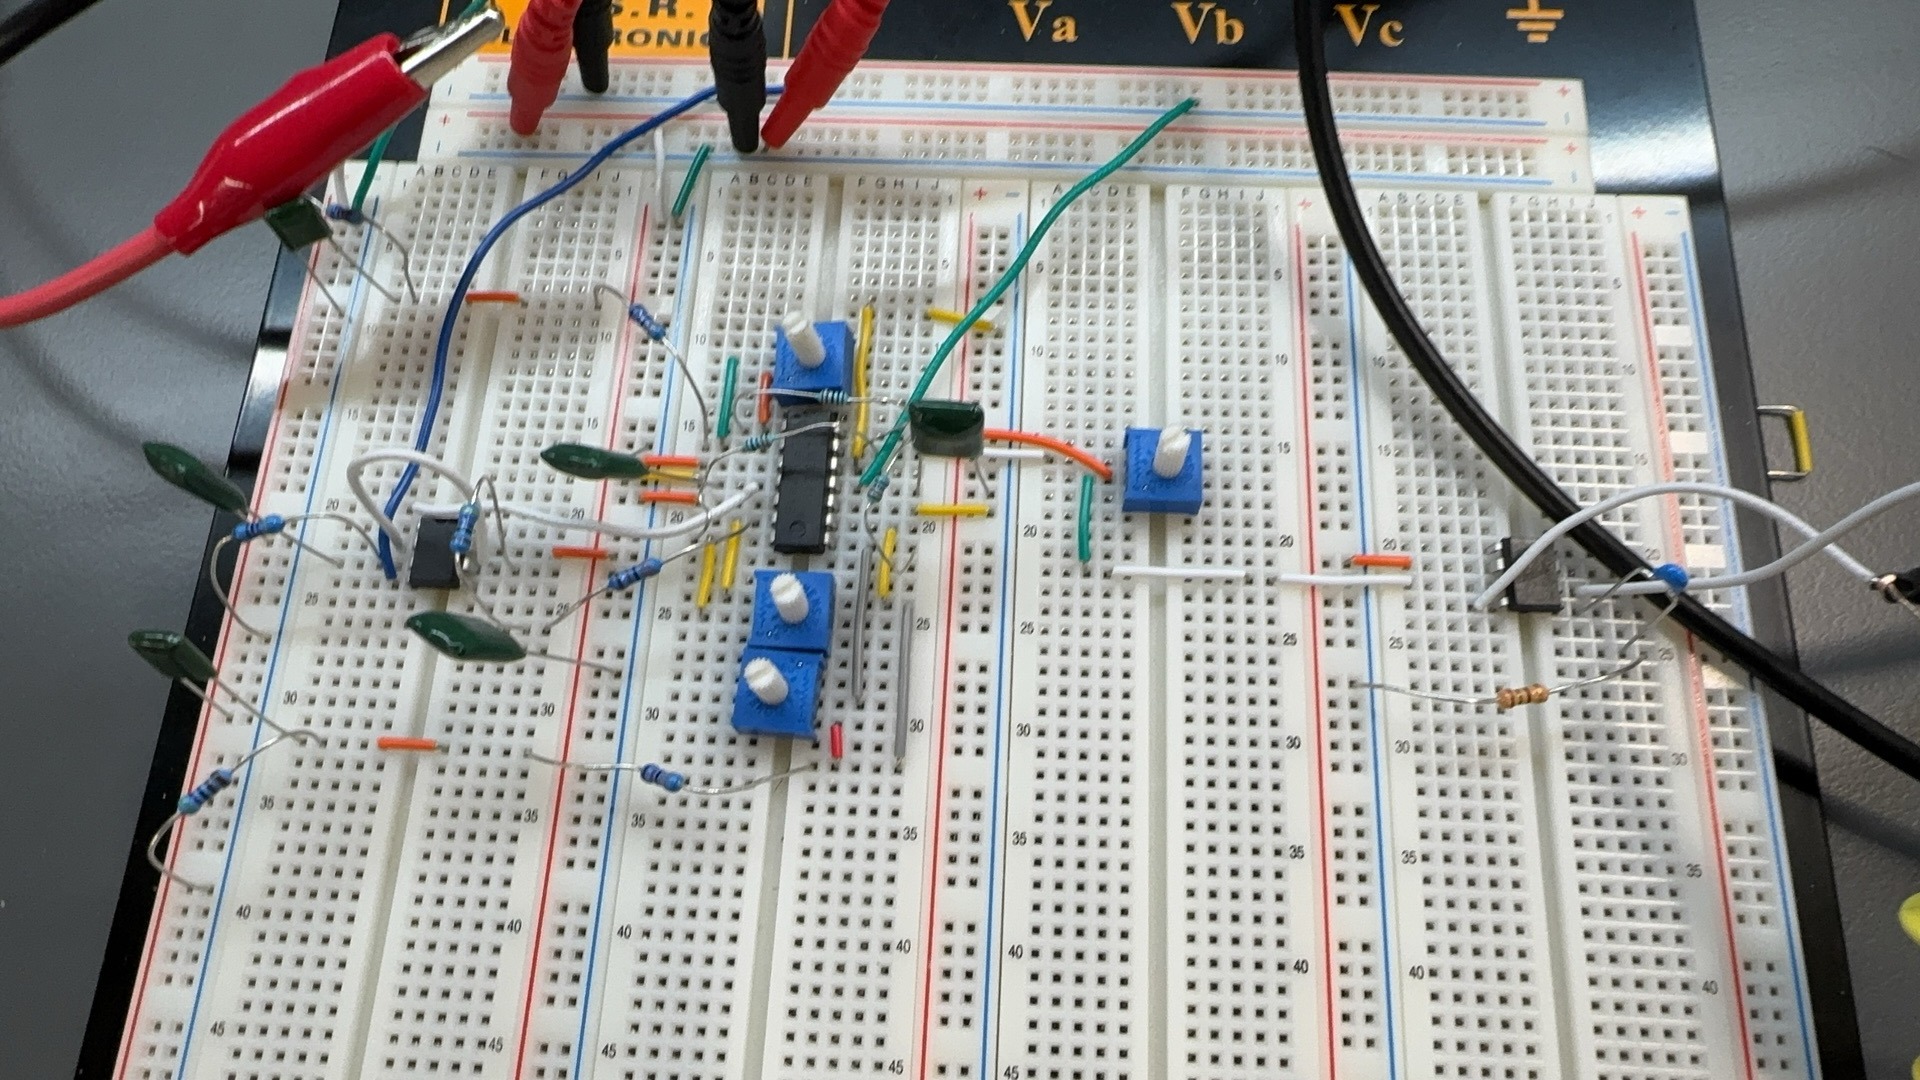
Three-Band Analog Audio Equalizer
A bass, mid, and treble tone control built from RC filters and op-amps. Designed in LTspice, breadboarded, and bench-tested against every spec.
- Analog Circuits
- Audio
- Op-Amps
- LTspice
Get in touch
Have a question or want to collaborate on a project? Send me a message and I'll get back to you!